Robot Path Simulation
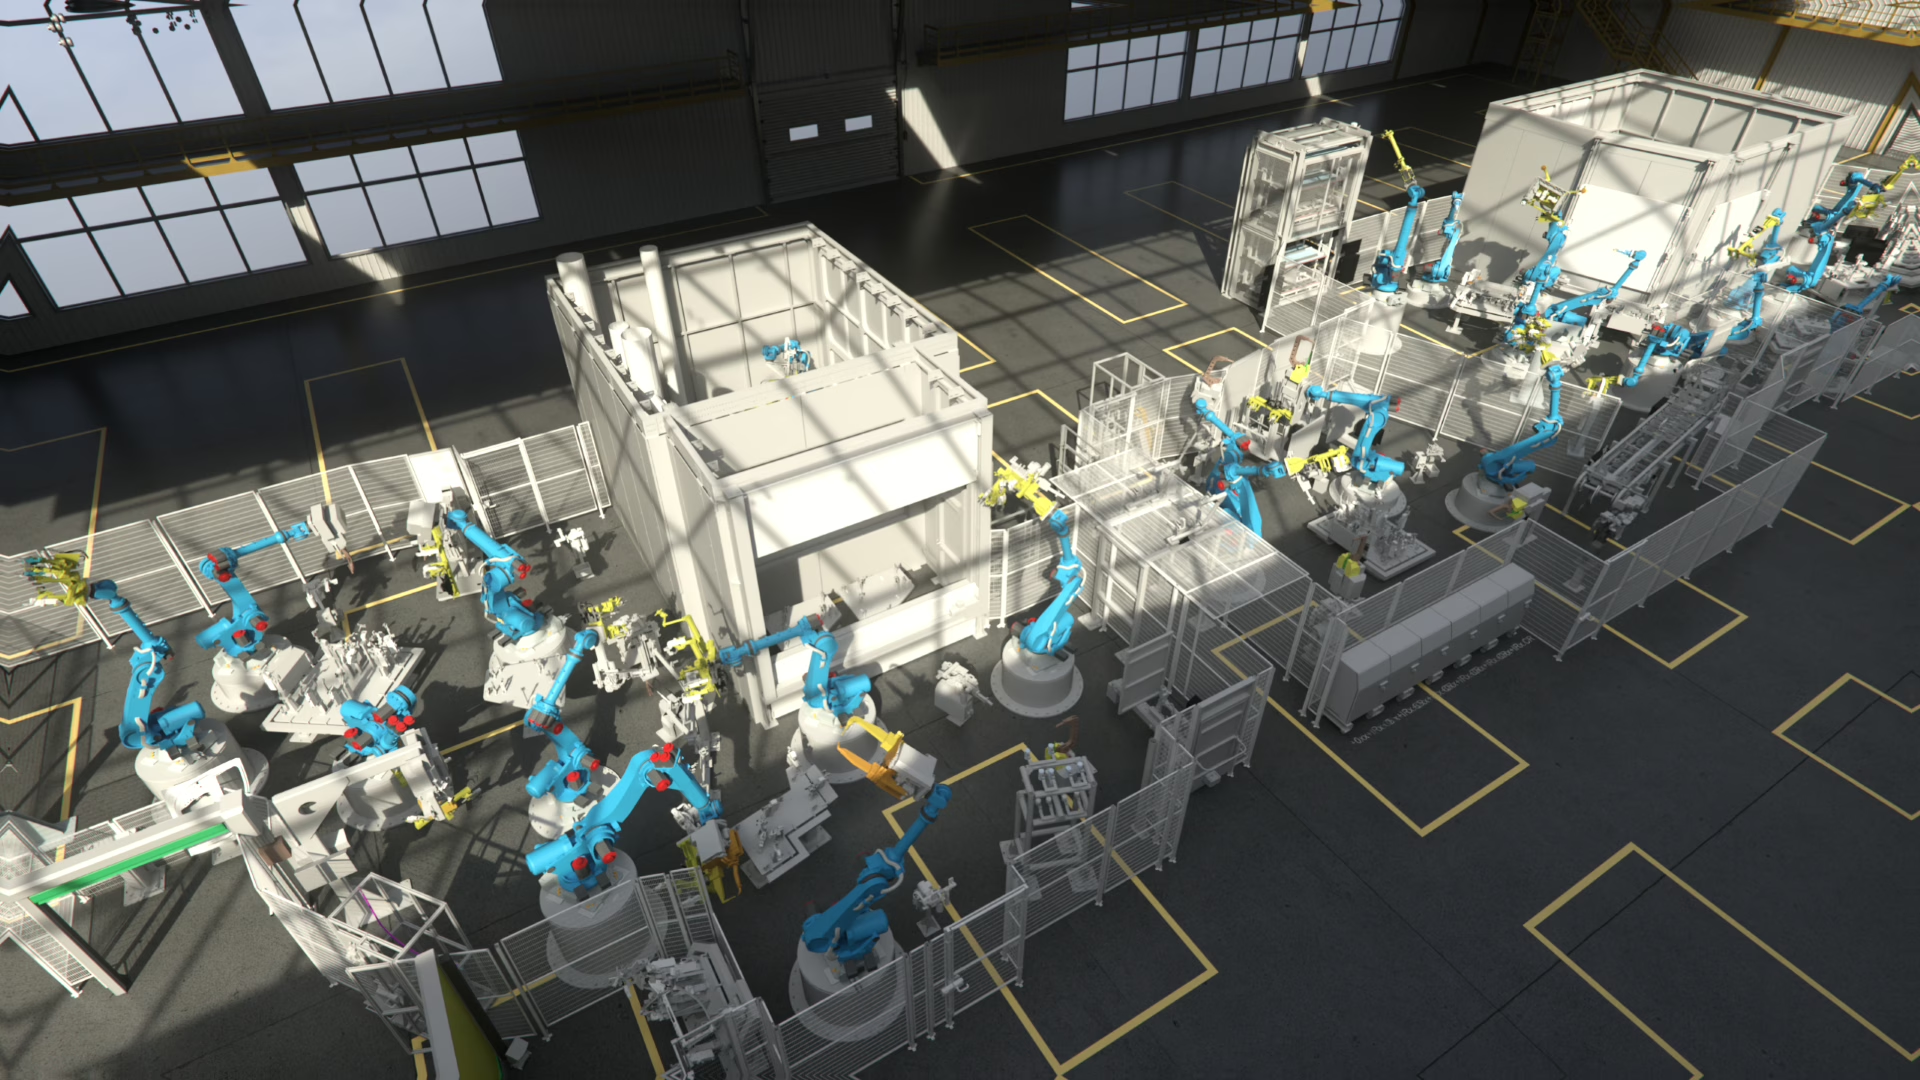
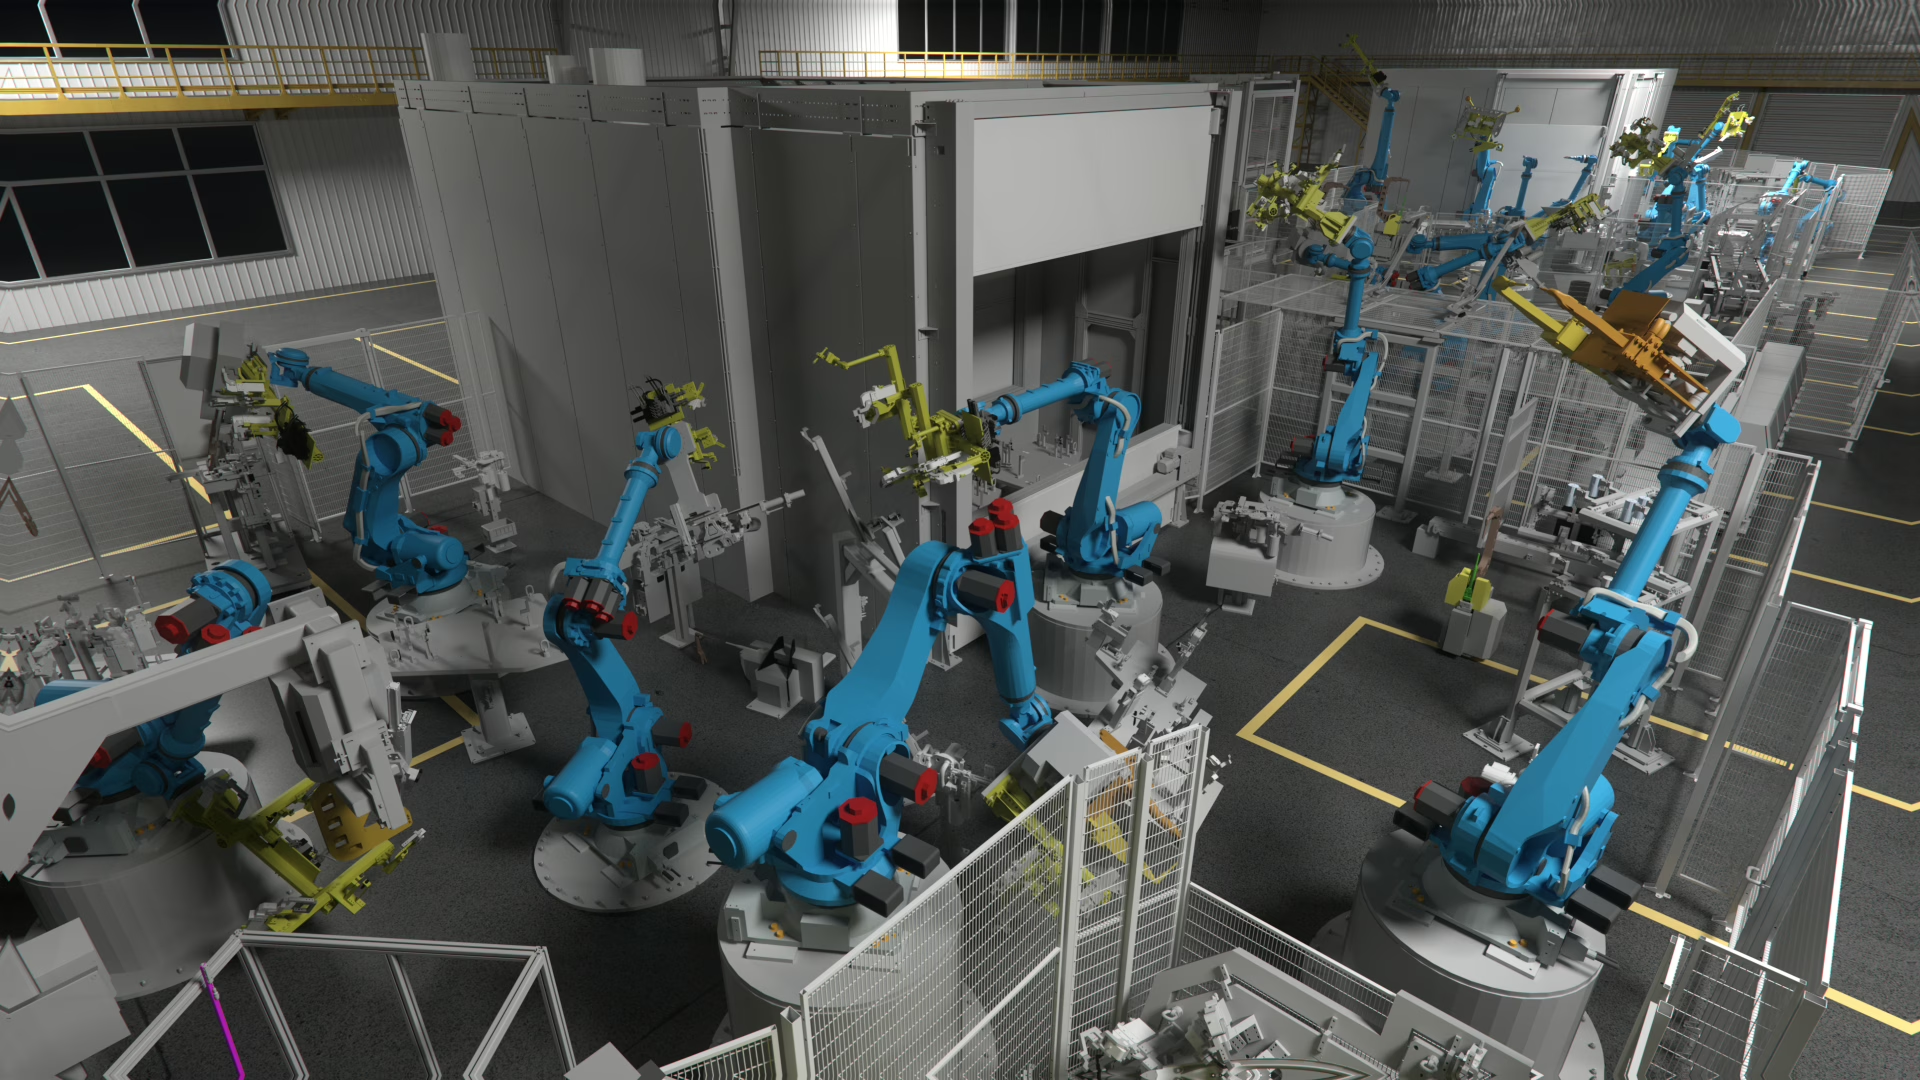
Simulate programmed robot movements and visualize motion behavior in a virtual production environment.
Entdecke alle Phasen der Automatisierung mit einem einheitlichen Ansatz.
Entdecke bewährte Anwendungsfälle für Tests, Validierung und Produktionsoptimierung.
Von der ersten Planung bis zu produktionsreifen Anlagen und automatisierten Engineering-Prozessen.
Entwickle zuverlässige Prozesse für die virtuelle Inbetriebnahme, industrielle Software und Wissen, das du immer wieder nutzen kannst.
Tools für die Digitale Fabrik
RF::SUITE
Eine vernetzte Plattform für Engineering, Simulation, Validierung und intelligenter Produktion.
RF::SUITE entdecken →
Wähle die passenden Werkzeuge für deinen Arbeitsablauf und verbinde sie in einer einheitlichen Engineering-Umgebung.
Von einzelnen Maschinen bis zu komplexen Produktionslinien: Wir verbinden Engineering, Simulation und Betrieb über den gesamten Lebenszyklus hinweg.
Industrien EntdeckenWir verbinden Simulation, virtuelle Inbetriebnahme und Know-how in industrieller Software für anspruchsvolle Produktionsumgebungen.
Wir beteiligen uns an nationalen und internationalen Forschungsprojekten zu digitalem Engineering, Automatisierung, künstlicher Intelligenz und nachhaltigen Produktionssystemen.
Resiliente, nachhaltige und anpassungsfähige industrielle Produktionssysteme.
→ 02 Forschungsprojekte REDRIVESResiliente Antriebstechnologien und robuste industrielle Produktionsprozesse.
→ 03 Forschungsprojekte DIGIKLEBDigitale Methoden für vernetzte Klebeprozesse und Qualitätskontrolle.
→ 04 Forschungsprojekte GENIUSIntelligente Ingenieurverfahren für datengetriebene Fertigungssysteme.
→Technologie und Erfahrung für zuverlässige industrielle Produktionssysteme.
Mehr über EKS InTec →Erfahre mehr über EKS InTec, unsere Standorte und deine Karrieremöglichkeiten – und nimm Kontakt mit unserem Team auf.
Robot Simulation & Validation
RF::RobSim enables engineers and programmers to simulate, test and validate industrial robot systems in a virtual environment. Robot programs, movements and cell layouts can be reviewed before physical commissioning.
RF::RobSim
RF::RobSim is the robot simulation module within the RF::SUITE. It provides a virtual environment for testing, optimizing and validating robot programs, movements and production cell layouts before they are executed on real systems.
Robot path simulation, reachability review, collision-critical motion analysis and cell layout validation support virtual commissioning preparation throughout the engineering lifecycle.
Key Features
RF::RobSim combines robot path simulation, reachability review, collision analysis and cell layout validation in one virtual environment for robot program validation and commissioning preparation.
Simulate programmed robot movements and visualize motion behavior in a virtual production environment.
Check whether target positions and movement sequences are feasible within the robot workspace.
Support the evaluation of spatial constellations and robot movements before they are used on real systems.
Review robots, tools, fixtures and surrounding equipment as part of a connected production setup.
Analyze robot behavior in a controlled virtual environment to support debugging and validation workflows.
Combine robot simulation with RF::YAMS, RF::ViPer and RF::SCOUT for connected virtual commissioning.
Inside RF::RobSim
RF::RobSim combines robot motion simulation, reachability analysis, collision review and connected commissioning workflows in a single virtual environment.
Simulate programmed robot movements and visualize motion sequences in a virtual production cell.
Review target positions, workspace limits and robot accessibility before physical testing.
Evaluate collision-critical constellations and movement conflicts within the robot cell.
Review cell layouts, multi-robot systems and spatial dependencies for commissioning preparation.
Connect robot validation with RF::SUITE modules for end-to-end virtual commissioning.
Typical Robot Validation Workflow
RF::RobSim supports a structured validation path from robot cell import to commissioning preparation.
Bring robot data, layouts and relevant cell context into the simulation environment.
Execute robot paths virtually and visualize motion behavior within the cell layout.
Review target positions, workspace limits and robot accessibility before physical testing.
Identify critical spatial constellations and movement conflicts early.
Use validation results to support commissioning, documentation and optimization.
RF::RobSim + RF::ViPer
RF::RobSim focuses on robot movement, reachability and cell validation. RF::ViPer adds the virtual periphery, signal behavior and PLC logic context. Together, both modules support a more complete virtual commissioning setup.
Simulate and review robot paths, reachability and cell layouts before physical testing.
Connect robot validation with virtual periphery, PLC logic and signal behavior.
Combine both modules for a more complete pre-commissioning validation workflow.
RF::SUITE Integration
RF::RobSim is part of the RF::SUITE ecosystem. It provides robot simulation and validation that connects with 3D simulation, virtual periphery, process analysis and virtual training.
Virtual 3D environment for production systems, material flow and process visualization.
Simulation of peripheral components, signals, fieldbus communication and automation behavior.
Robot program validation, motion simulation, reachability review and cell layout validation.
Process analysis, transparency, validation and optimization based on production data.
Training environments based on virtual production systems and RF::SUITE workflows.
Application Scenarios
RF::RobSim supports robot validation across programming, layout review, collision analysis and virtual commissioning preparation.
Validate robot programs and movement sequences before real execution.
Review whether target positions can be reached within the available robot workspace.
Identify collision-critical movements and spatial conflicts in the virtual robot cell.
Evaluate robot placement, fixtures, tools and surrounding equipment.
Support review of movement timing and robot sequence behavior.
Prepare robot-related validation steps before physical commissioning starts.
Downloads / Resources
Download product information, technical material or project documentation for RF::RobSim.
Short introduction to RF::RobSim and its role in robot simulation and virtual commissioning.
Download PDFDetails about simulation capabilities, integration and validation workflows.
Request DocumentLearn how RF::RobSim connects with RF::YAMS, RF::ViPer and RF::SCOUT.
RF::SUITE entdeckenFrequently Asked Questions
Learn more about robot simulation, validation workflows and practical applications of RF::RobSim.
RF::RobSim is used to simulate, validate and optimize industrial robot movements, robot programs and production cell layouts in a virtual environment.
Yes. RF::RobSim can be used to review whether target positions, tool orientations and movement sequences are feasible within the robot workspace.
RF::RobSim supports the evaluation of collision-critical movements and spatial constellations within robot cells before they are executed on real systems.
Yes. RF::RobSim supports early virtual validation before physical commissioning, helping engineering teams review robot behavior before the complete real system is available.
Yes, RF::RobSim can support validation scenarios involving multiple robots and their spatial dependencies within a production cell.
RF::RobSim focuses on robot movement and cell validation, while RF::ViPer simulates virtual periphery, signals and PLC logic. Together they support connected virtual commissioning workflows.
No. RF::RobSim supports earlier virtual validation and can reduce physical testing effort, but final validation still depends on the real system and project requirements.
Get Started
Use RF::RobSim to simulate robot motion, review cell layouts and support validation before physical commissioning.