

Evaluate
Define geometry & paths
Import cell layout, tooling, and robot trajectories.

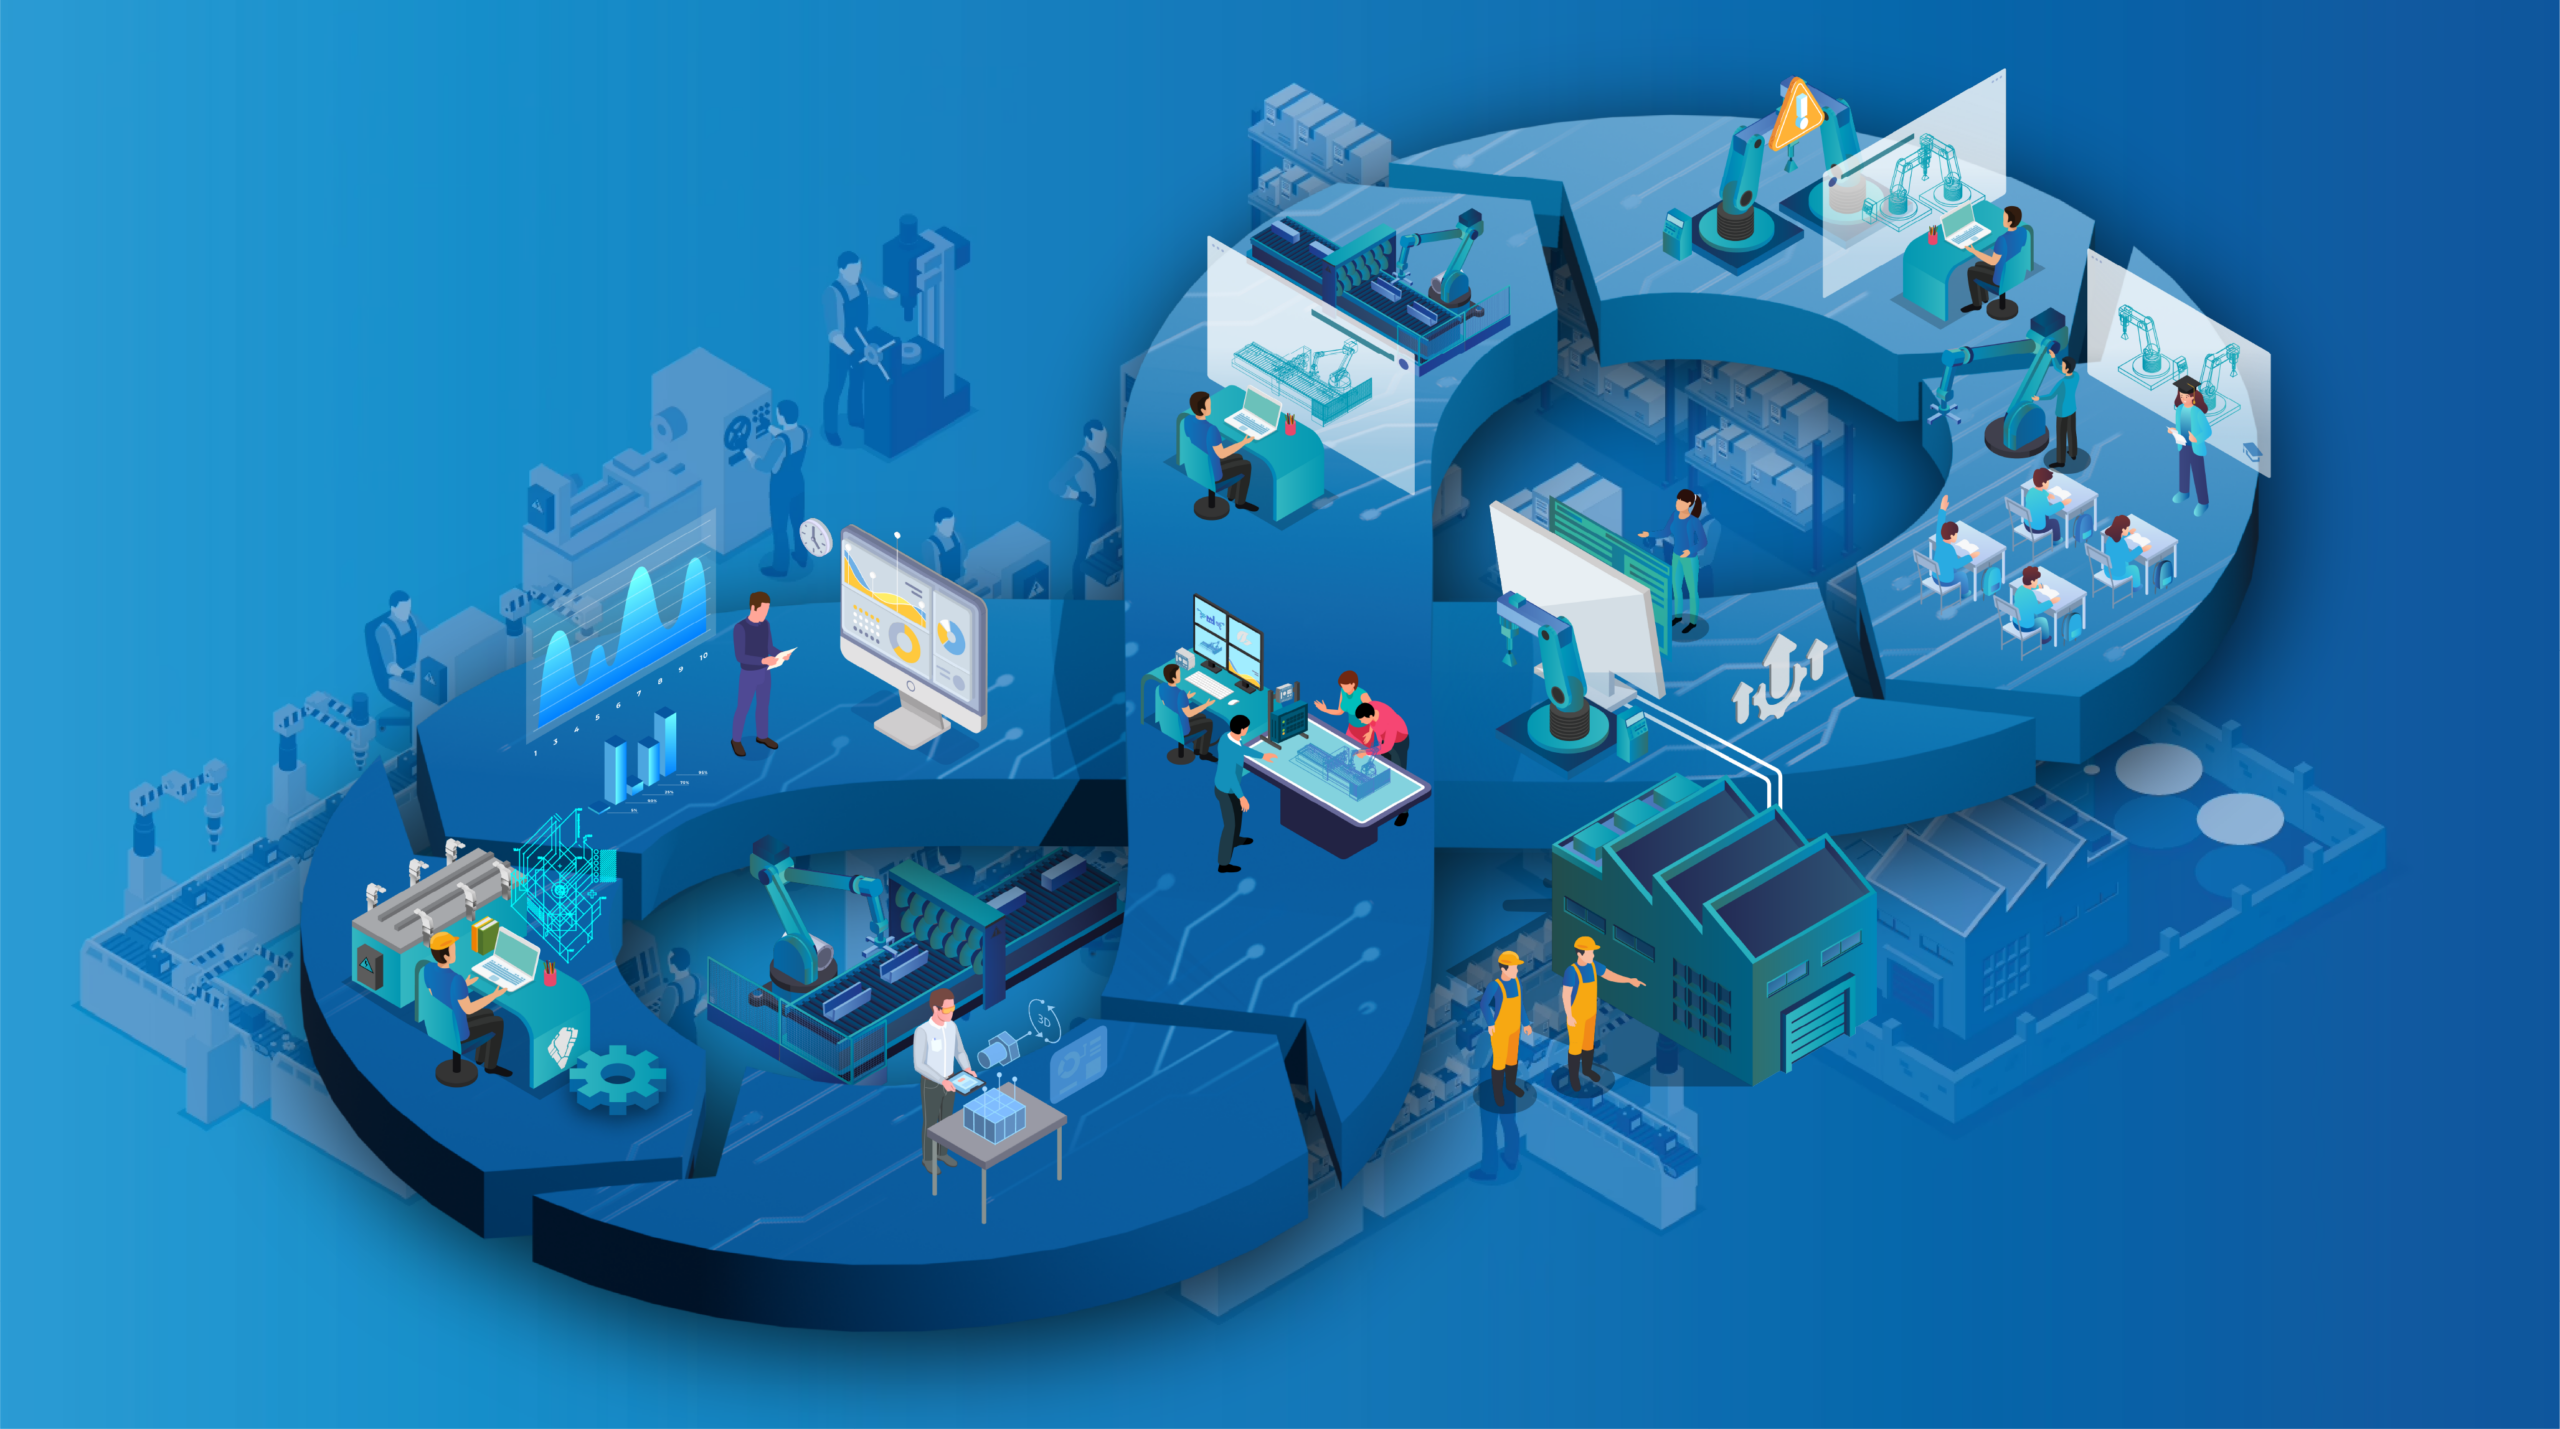
Move through every stage of automation with one connected approach.
Explore proven use cases for testing, validation and production optimization.
From initial planning to production-ready systems and automated engineering workflows.
Build reliable virtual commissioning workflows, industrial software and reusable expertise.
 Tools for the Digital Factory
RF::SUITE
One connected platform for engineering, simulation, validation and production intelligence.
Explore RF::SUITE →
Choose the tools your workflow needs and connect them within one consistent engineering environment.
 RF::YAMS3D simulation and material flow
→
 RF::ViPerVirtual periphery simulation
→
 RF::RobSimRobot simulation
→
 RF::SCOUTAnalysis and optimization
→
 RF::CEREBData intelligence platform
→
 RF::GUARDFixture simulation and validation
→
 RF::FSBoxHardware for fieldbus simulation
→
 RF::EdDiVirtual operator and PLC training
→
 RF::VPM ToolProject and model preparation
→
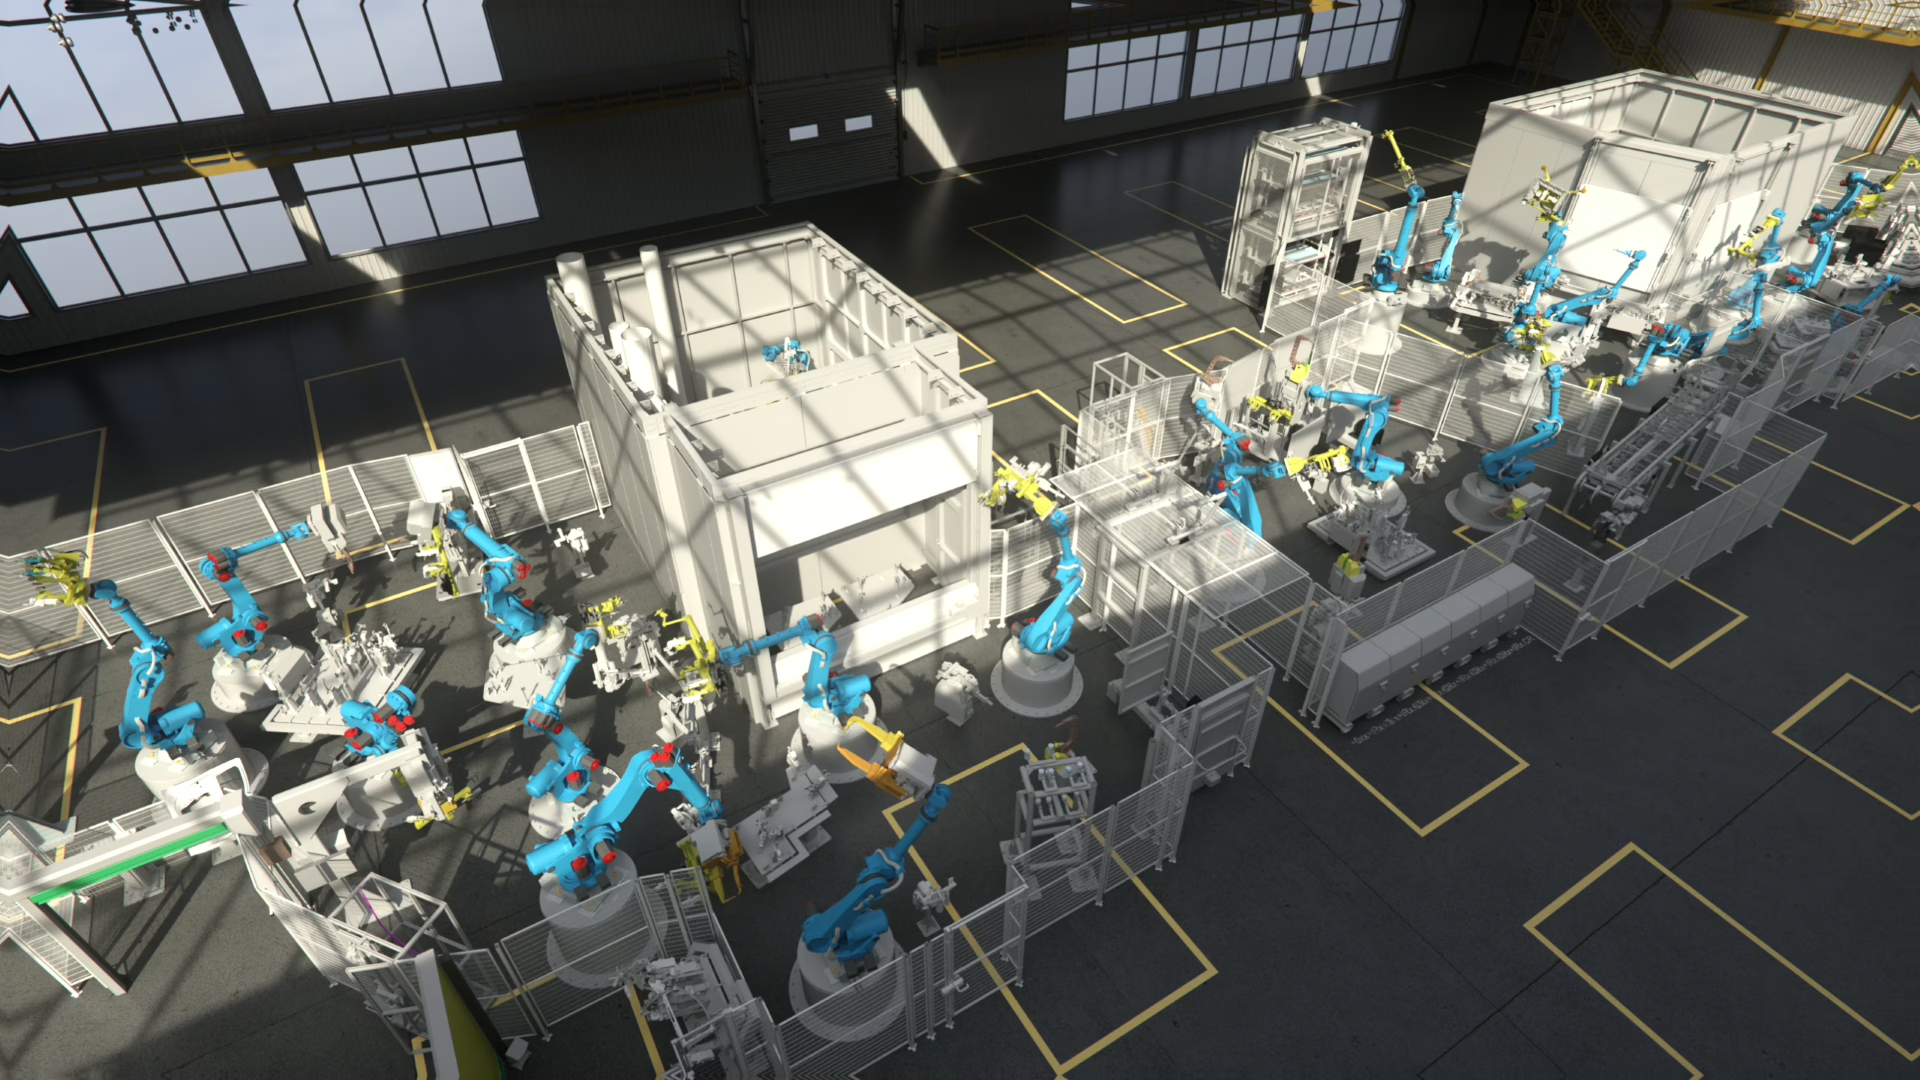
From individual machines to complex production lines: we connect engineering, simulation and operation throughout the entire lifecycle.
We combine simulation, virtual commissioning and industrial software expertise across demanding production environments.
Courses, dates and individual training
Partnerships and research projects
Products, licences and technical advice
Company, projects and general topics
Tell us briefly who you are and why you would like access.